Russian air defense intercepts Ukrainian drone near oil facility in Ryazan Oblast
What happened
Russian air defense personnel reportedly used an Igla shoulder-fired missile system to shoot down a Ukrainian FPV or Liutyi-type kamikaze drone near an oil refinery facility in Ryazan Oblast on October 5, 2026. According to the report, the engagement occurred just before the drone reached its target. One air-defense engagement was recorded, with the drone eliminated before impact.
Context and assessment
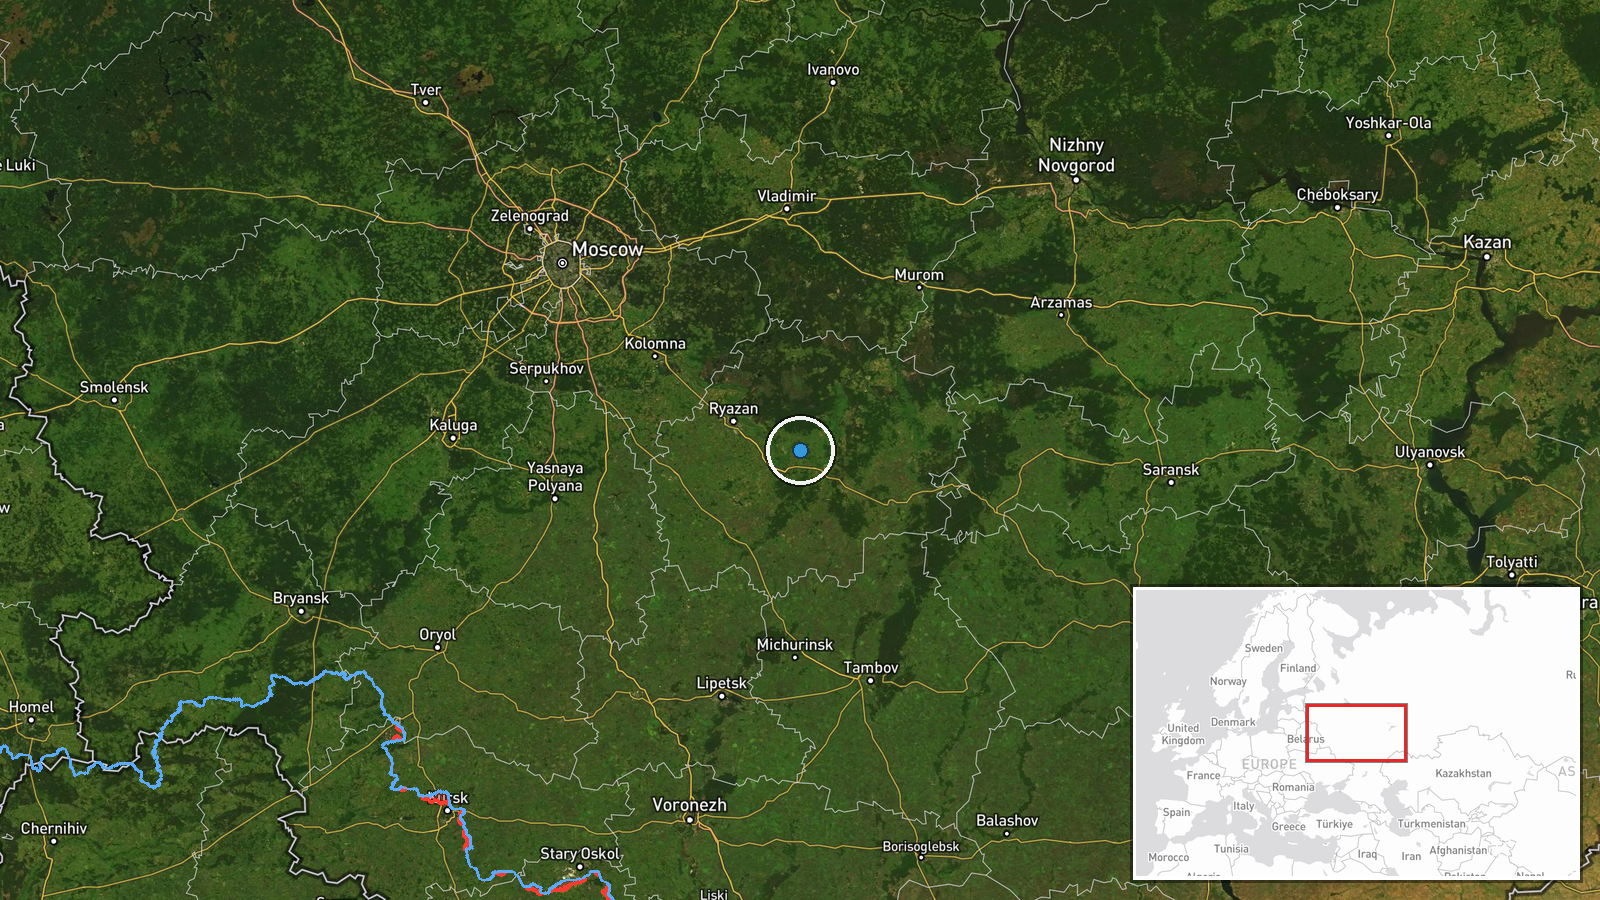
Ryazan Oblast, located approximately 200 kilometers southeast of Moscow, hosts significant petroleum infrastructure critical to Russian energy supply. Ukrainian drone operations against Russian refineries and energy facilities have intensified over the conflict, targeting fuel production capacity to degrade Russian military logistics. The use of tactical air defenses like the Igla system to counter unmanned threats reflects Russian efforts to protect rear-area infrastructure from increasing long-range strike operations. Successful intercepts suggest Ukrainian drone penetration attempts continue despite Russian air defense deployments, indicating sustained pressure on Russian energy targets.
Sources and confidence
Single report from X account @ConflictTR, which specializes in conflict coverage. No cross-confirmation from additional independent sources. Confidence rated 6.0 due to sole-source reporting and low geographic precision confidence. Verification by Ukrainian official sources, additional conflict observers, or Russian acknowledgment would substantially raise confidence. Specific facility identification and damage assessment details would further corroborate the account.
Location
Ryazan Oblast, Russia, approximately 200 kilometers southeast of Moscow. Coordinates place the event near settlement-level precision in the region containing multiple petroleum refineries. The specific oil facility targeted was not identified in available reporting. Nearby Ryazan city serves as the oblast administrative center.
▶ View this event on the live map
Intel Mapper aggregates open-source reports from monitored Telegram and X channels, geolocates them, cross-checks duplicates across sources and assigns a confidence score. Entries are updated as new confirmations arrive. Read how we verify events.