Russian Shahed drones transit Kyiv Oblast; additional incursion from Uzyn
What happened
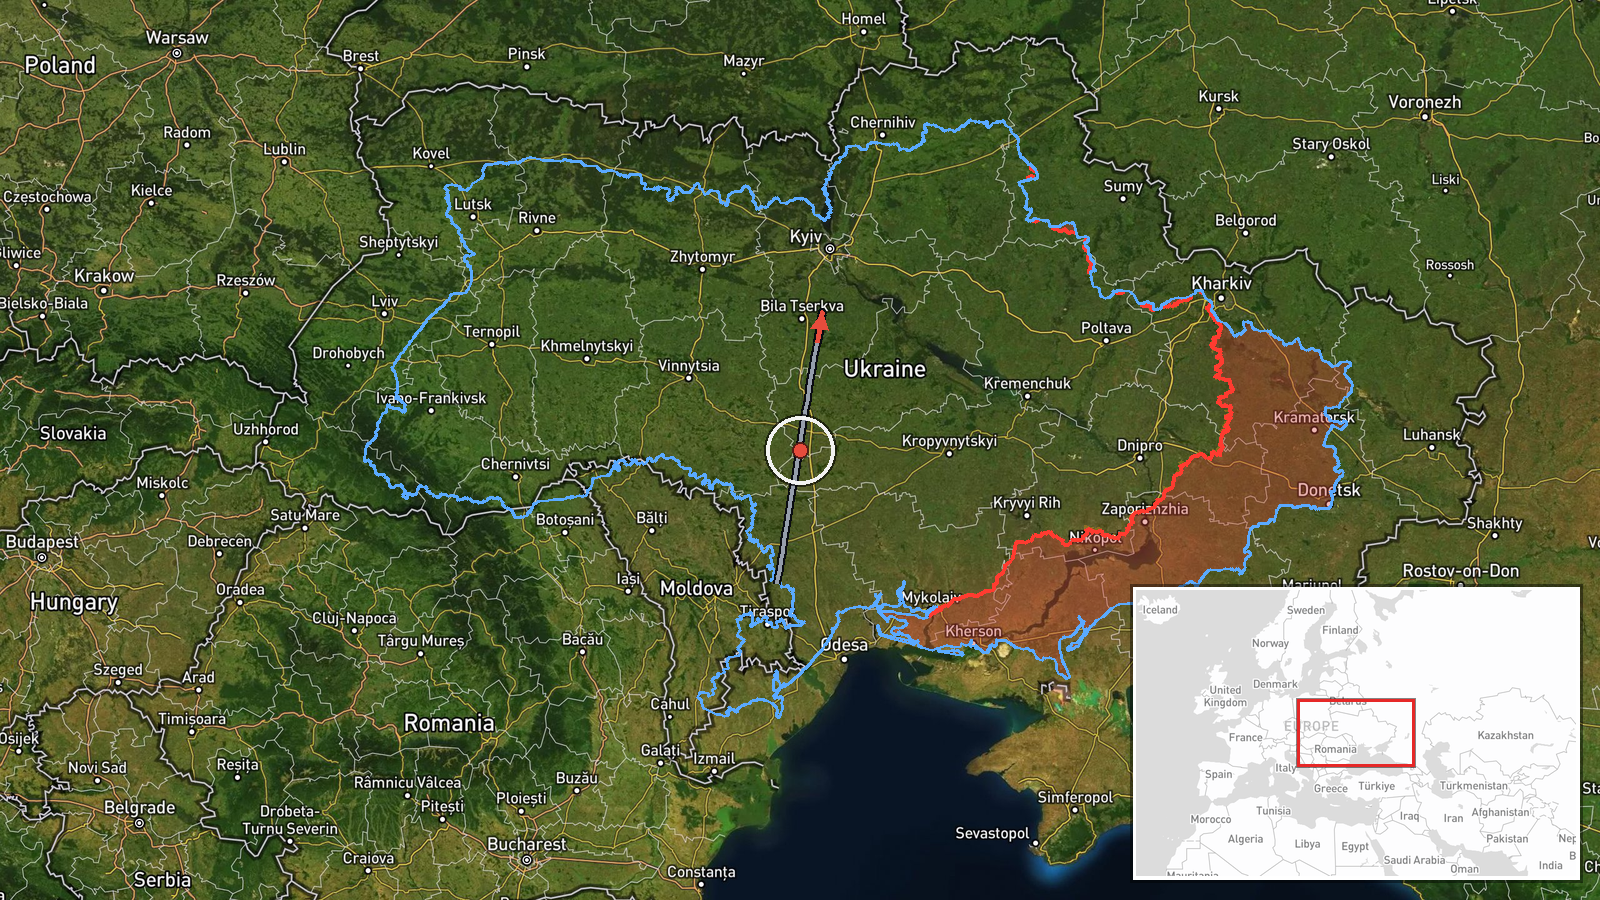
Russian Shahed-type kamikaze drones were detected in transit over Kruzhivka in Kyiv Oblast on 21 September at 00:46 UTC, according to Telegram channel @war_monitor. The report also indicates another drone was tracked traveling from Uzyn toward the Obukiv sector. These were drone transits rather than confirmed strikes, and the drones' ultimate targets or whether they were intercepted remain unreported.
Context and assessment
This incident follows a pattern of Russian drone activity over Kyiv Oblast documented on 20 September, when two Shahed-type UAVs were detected transiting through the Chornobyl Exclusion Zone and a single drone approached Kyiv vicinity, prompting air raid alerts. The use of jet-powered kamikaze drones continues to test Ukrainian air defenses in the region. Concurrent Ukrainian operations, including the destruction of a Russian Buk-M3 air defense system near Zaporizhzhia on 19–20 September, suggest ongoing mutual attrition in air defense assets. The frequency of transits may indicate Russian drone operations sustained at scale, though the tactical objective of these particular flights is unclear.
Sources and confidence
Reported by Telegram channel @war_monitor only; no cross-confirmation from other open-source channels noted. Single-source reporting limits confidence to 6.0 out of 10. Confidence would increase with corroboration from additional Ukrainian military channels, air defense confirmations, or reports of interception. Lack of casualty or damage reports may indicate successful Ukrainian air defense or incomplete reporting.
Location
Kruzhivka is a settlement in Kyiv Oblast approximately 45 kilometers northwest of central Kyiv, situated in relatively flat terrain typical of the region. The Obukiv sector lies further northwest along a corridor toward the Uzyn departure point. This corridor has seen repeated drone transits, suggesting a consistent flight path used by Russian operations.
Related events nearby
- Russian Shahed-type reactive UAV (kamikaze drone) detected in transit across Kyiv Oblast airspace. Air alert i2026-09-20 14:13 UTC · Drone Transit · Kyiv Oblast, Ukraine
- Air raid alert issued across Kyiv region as Russian Shahed-type reactive UAV (kamikaze drone) spotted in trans2026-09-20 13:47 UTC · Siren · Kyiv, Ukraine
- Ukrainian Defense Ministry announces special operations forces (Patili commandos) ready for deployment. Visual2026-09-20 14:50 UTC · Deployment · Kyiv, Ukraine
- Ukrainian commentary on wartime resilience: Ukraine has transitioned from near-collapse in 2022 (3-day dash to2026-09-20 13:16 UTC · Statement · Kyiv, Ukraine
- Ukrainian President Zelensky announces Ukraine struck multibillion-dollar Russian war-financing facilities in 2026-09-20 10:16 UTC · Statement · Kyiv, Ukraine
▶ View this event on the live map
Intel Mapper aggregates open-source reports from monitored Telegram and X channels, geolocates them, cross-checks duplicates across sources and assigns a confidence score. Entries are updated as new confirmations arrive. Read how we verify events.