Russian Shahed-136 drone transits Kyiv; part of sustained overnight attack wave
What happened
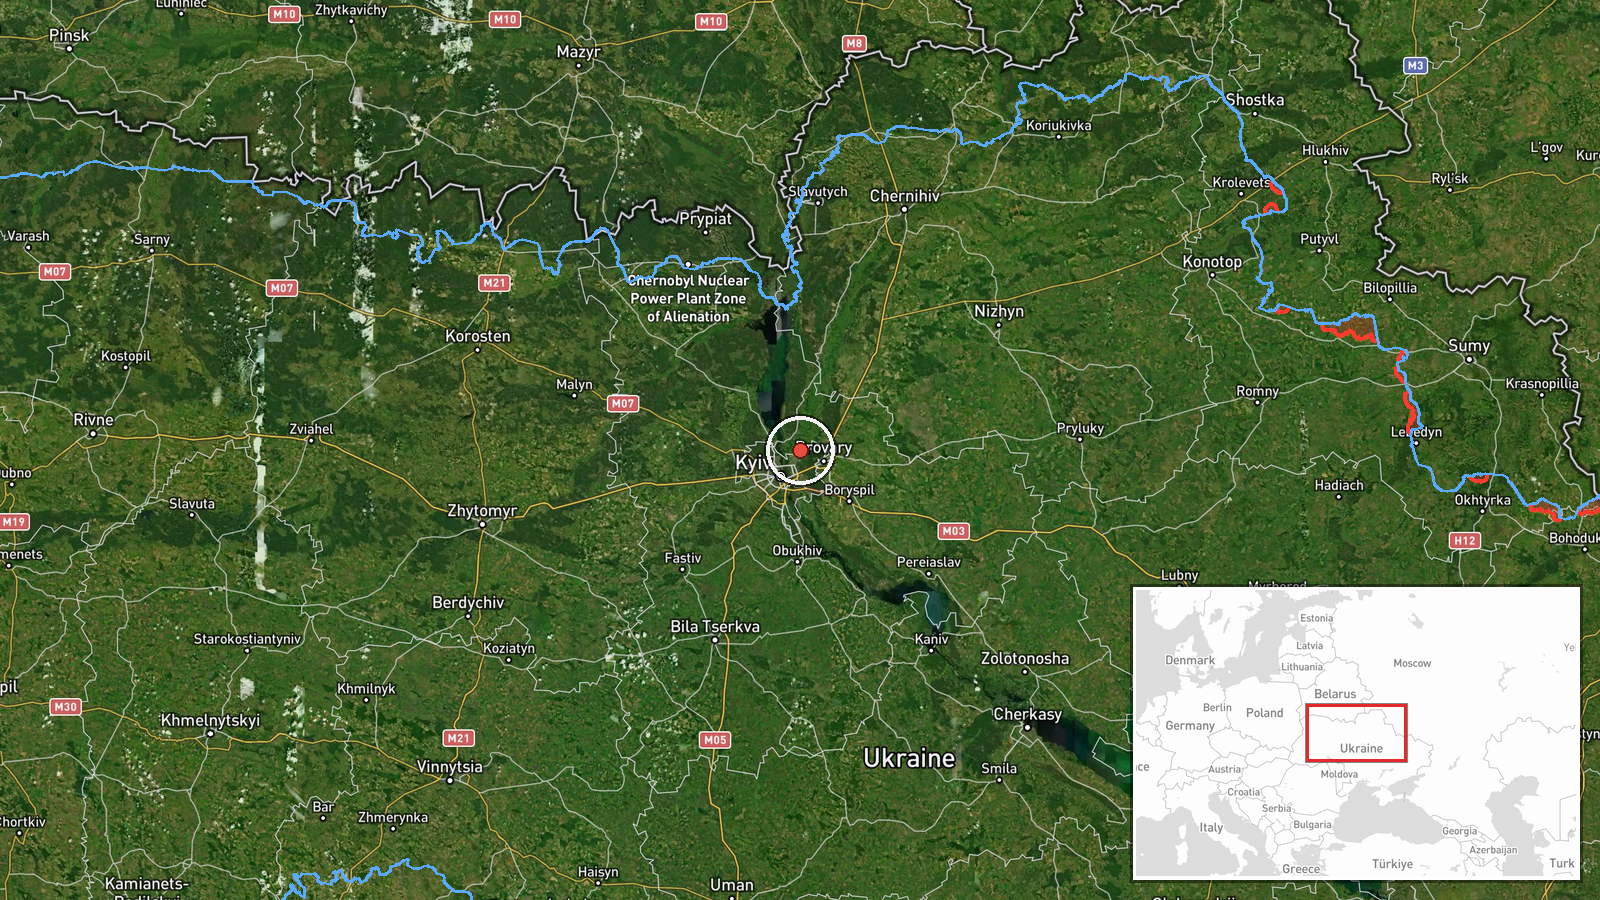
Ukrainian air monitoring detected one Russian Shahed-136 reactive drone in transit over Kyiv on October 4, originating from Pohrebi in Kyiv Oblast and heading northwest through Troieshchyna District. The report comes from Telegram channel @war_monitor and provides no impact assessment. This sighting follows multiple drone detections across the Kyiv region during the preceding night.
Context and assessment
Troieshchyna District, located in northern Kyiv, remains under persistent drone surveillance and transit activity. The detection fits an established pattern of Russian drone operations targeting the capital region from multiple approach vectors. Related reports from October 3 document at least four separate Shahed-136 transits across Brovarskyi and Troieshchyna districts, culminating in a major overnight barrage in which Ukrainian air defense intercepted 131 drones. The consistent flow of reconnaissance and attack drones through northeastern Kyiv approaches suggests Russian forces are maintaining pressure on civilian and military infrastructure, testing air defense response capabilities and saturation thresholds.
Sources and confidence
Report sourced from single Telegram channel (@war_monitor), a Ukrainian air monitoring account. No cross-confirmation from other channels noted. Confidence score of 6.0 reflects single-source reporting and absence of independent verification. Score would increase with confirmation from additional Ukrainian official channels; would decrease if impact claims or subsequent interception details contradicted the initial report.
Location
Pohrebi settlement in Kyiv Oblast marks the detection origin point, with observed flight path heading northwest through Troieshchyna District in northern Kyiv. Troieshchyna lies approximately 10 kilometers northeast of central Kyiv. High confidence in settlement-level precision based on Ukrainian air monitoring methodology and geographic specificity of the original report.
Related events nearby
- One Russian reactive/jet-powered drone (Shahed-136 variant) detected transiting over Troieshchyna District, Ky2026-10-03 22:38 UTC · Drone Transit · Troieshchyna District, Kyiv, Ukraine
- One reactive (jet-propelled) Shahed-variant drone detected transiting Brovary district, Kyiv Oblast. No impact2026-10-03 03:37 UTC · Drone Transit · Brovary, Kyiv Oblast, Ukraine
- One Russian reactive/jet-powered drone (Shahed-136 variant) detected transiting over Brovarskyi District, Kyiv2026-10-03 22:33 UTC · Drone Transit · Brovarskyi District, Kyiv Oblast, Ukraine
- One Russian reactive/jet-powered drone (Shahed-136 variant) transiting from Bobrovytsya toward Brovarskyi Dist2026-10-03 22:28 UTC · Drone Transit · Brovarskyi District, Kyiv Oblast, Ukraine
- Ukrainian air defense intercepted 131 Russian attack drones (Shahed, Geran, decoys) launched from four directi2026-10-03 06:24 UTC · Air Defense · Kyiv, Kyiv Oblast, Ukraine
▶ View this event on the live map
Intel Mapper aggregates open-source reports from monitored Telegram and X channels, geolocates them, cross-checks duplicates across sources and assigns a confidence score. Entries are updated as new confirmations arrive. Read how we verify events.